
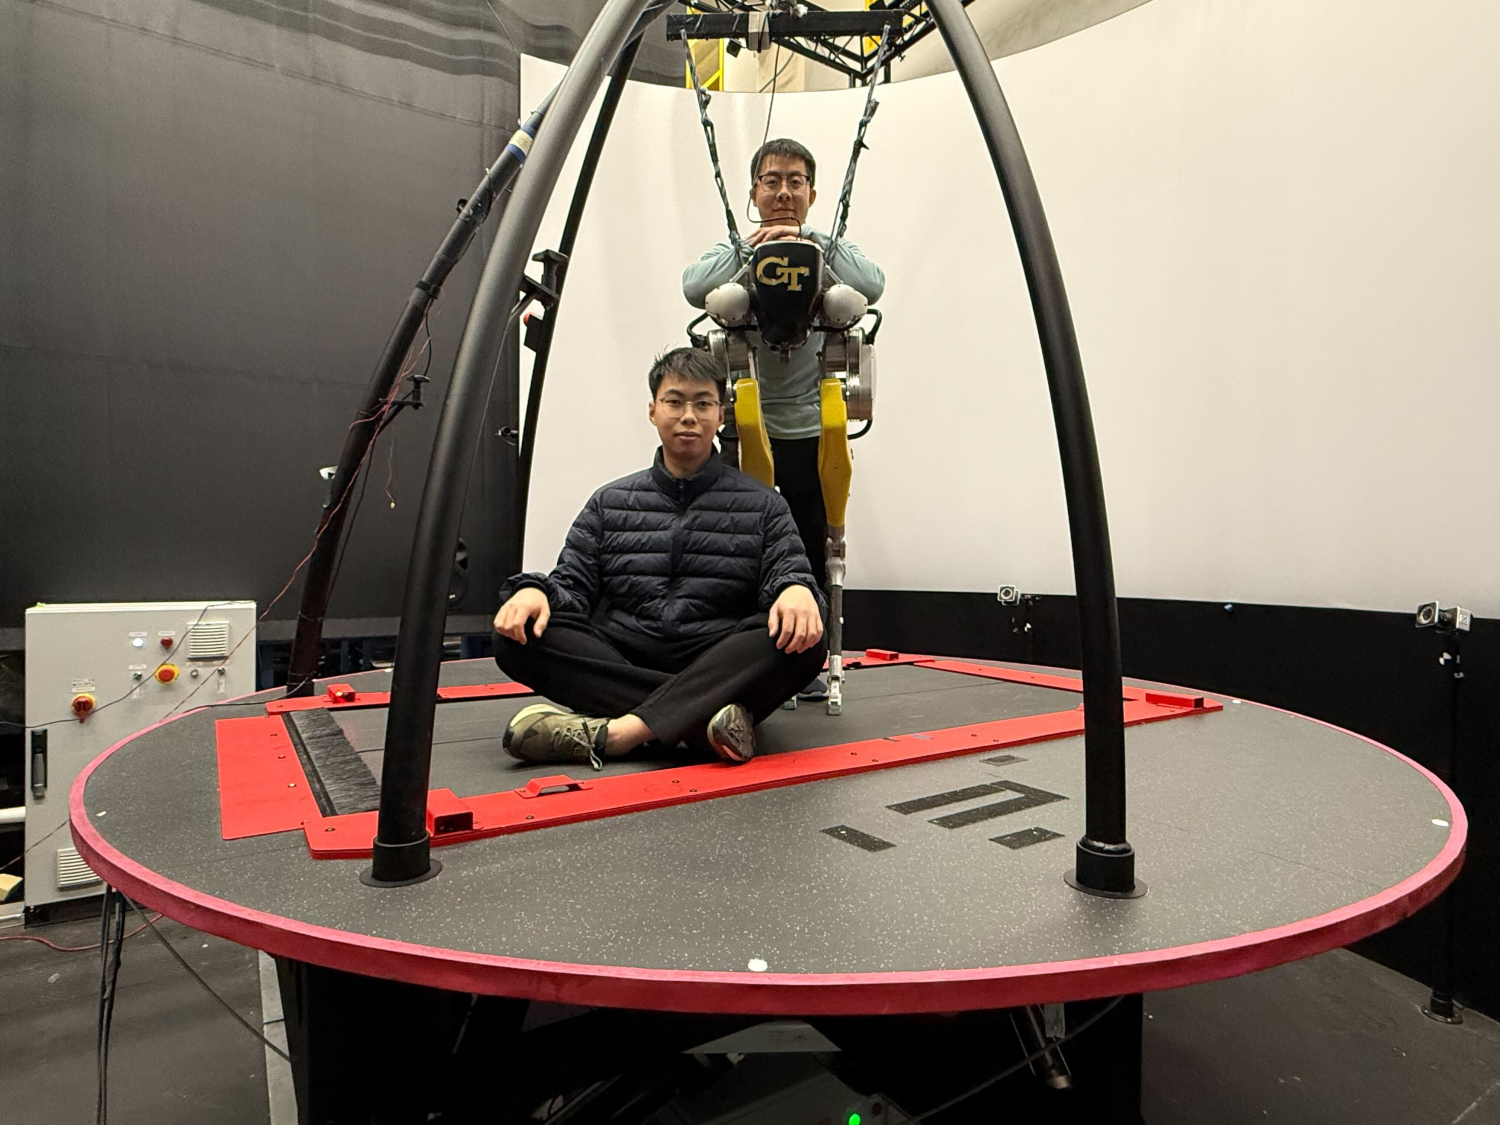
Yipu Chen (seated) and Zhaoyuan Gu (standing) on the CAREN treadmill system
"Humanoid robots are coming."
While this statement might cause anxiety for some, for one Georgia Tech research team, working with humanlike robots couldn't be more exciting.
Bipedal — or two-legged — autonomous robots can be quite agile. This makes them useful for performing tasks on uneven terrain, such as carrying equipment through outdoor environments or performing maintenance on an ocean-going ship. However, unstable or unpredictable conditions also increase the possibility of a robot wipeout.
The researchers, led by Ye Zhao, director of the Georgia Tech Laboratory for Intelligent Decision and Autonomous Robots (LIDAR), and Zhaoyuan Gu, a robotics Ph.D. student, wanted to develop a real-time planning and control framework that guarantees a robot's safety and recovery when traversing difficult terrain. The autonomous nature of this framework means the robots can make their own decisions without direct assistance from a human. For example, if an unexpected obstacle appears in its path, a robot equipped with this new framework could catch itself instead of falling.
Until now, there's been a significant lack of research into how a robot recovers when its direction shifts — for example, a robot losing balance when a truck makes a quick turn. The team aims to fix this research gap.
The Cassie robot walks confidently on the CAREN treadmill, making adjustments to its gait as the platform moves.
Putting the Project Pieces Together
In an IEEE Transactions on Robotics paper, the researchers describe a first-of-its-kind strategy that gives robots a clear set of rules for reacting when something changes in its path. These rules help the robot make quicker decisions and take more confident steps. When the robot senses that its current plan might not keep it stable, it uses these rules to adjust its next few steps, so it can continue moving safely. In earlier experiments, which lacked this framework, two-legged robots struggled to identify a solution for stability and were prone to falling.
The researchers implemented the new framework with Cassie, a two-legged robot. Inside Tech's 3,000-square-foot Human Augmentation Core Facility, the Cassie robot confidently walks on a Computer-Aided Rehabilitation Environment (CAREN) — a treadmill system that can be programmed to move in any direction at different times. When the team realized CAREN is limited in how much force it can inflict, they added a BumpEm system, which creates a stronger jerk to further stress-test Cassie's gait.
The Results
Through these experiments, the researchers found that their new programming framework outperforms state-of-the-art methods with more certainty, faster decision-making, higher collision avoidance, and the ability to reliably walk on moving platforms and varying types of terrain.
"The results we got through this project are very impressive. They're the most comprehensive and extensive hardware results we've published so far," said Zhao, who is a Woodruff Faculty Fellow and associate professor in the George W. Woodruff School of Mechanical Engineering.
Though significant, the real-world results weren't perfect. The robot doesn't perform as well when moving downhill, which requires it to take riskier steps and walk less efficiently. However, the only time Cassie completely failed to recover its gait was during a difficult scenario involving a very wide step and a cross-legged maneuver. Recovery simply wasn't feasible given the spatial limits of the narrow treadmill.
Next Steps for Walking Robots
Overall, the researchers' framework increases by 81% Cassie's ability to recover from instability. The team noted that bipedal stability in robotics needs further research. If these walking robots are to be fully integrated into our society, they must be reliable.
"This paper may serve as a foundation for continued work on walking robots," said Zhao. "Our work may inspire further research that can imitate or learn from the framework we've created."
Other ways of walking recovery are yet to be tested. For example, humans often hop to counteract instability or uneven footing; mirroring this with two-legged robots could be the next step in the team's research.
They would like to eventually enable the use of autonomous two-legged robots in marine environments, where ship maintenance and operations require risky, strenuous labor. Ideally, these robots could reliably, safely, and efficiently perform these kinds of tasks.
The project will be tested at sea through the Office of Naval Research in Arlington, Virginia.
"Humanoid robots are coming to your homes, coming to the factories, coming to logistics. They're going to show up on the street. It's exciting," said Gu.
Robotics engineers should consider not only a robot's mechanical design, but also its algorithms, intelligence, and brain. Being able to safely and regularly interact with these robots requires this foundational work.
"Robust-Locomotion-By-Logic: Perturbation-Resilient Bipedal Locomotion via Signal Temporal Logic Guided Model Predictive Control." https://doi.org/10.1109/TRO.2025.3582820
Funding for this research is provided by the Office of Naval Research Young Investigator Program and the National Science Foundation CAREER Program.
Researchers on this project include LIDAR Director Ye Zhao, Ph.D. student Zhaoyuan Gu, and master's students Yuntian Zhao, Yipu Chen, and Rongming Guo. Other contributors from the Physiology of Wearable Robotics Lab include Gregory Sawicki, director, and Jennifer Leestma (Ph.D. ROBO, 2024).
This research is also supported by the Agile Locomotion and Manipulation team, part of Georgia Tech's Vertically Integrated Projects program.

Writer: Chloe Morris
Media Contact: Shelley Wunder-Smith, Director of Research Communications